Where is the plume, how much is coming out, where does it come from, how often does it happen. Differentiable transport models (Gaussian plume and puff, Lagrangian particles, Eulerian finite volumes) and the Bayesian and variational machinery to invert them, for any passive tracer: methane, CO₂, NO₂, SO₂, smoke or heat. Everything is JAX:
jit,vmapandgradthrough the physics.
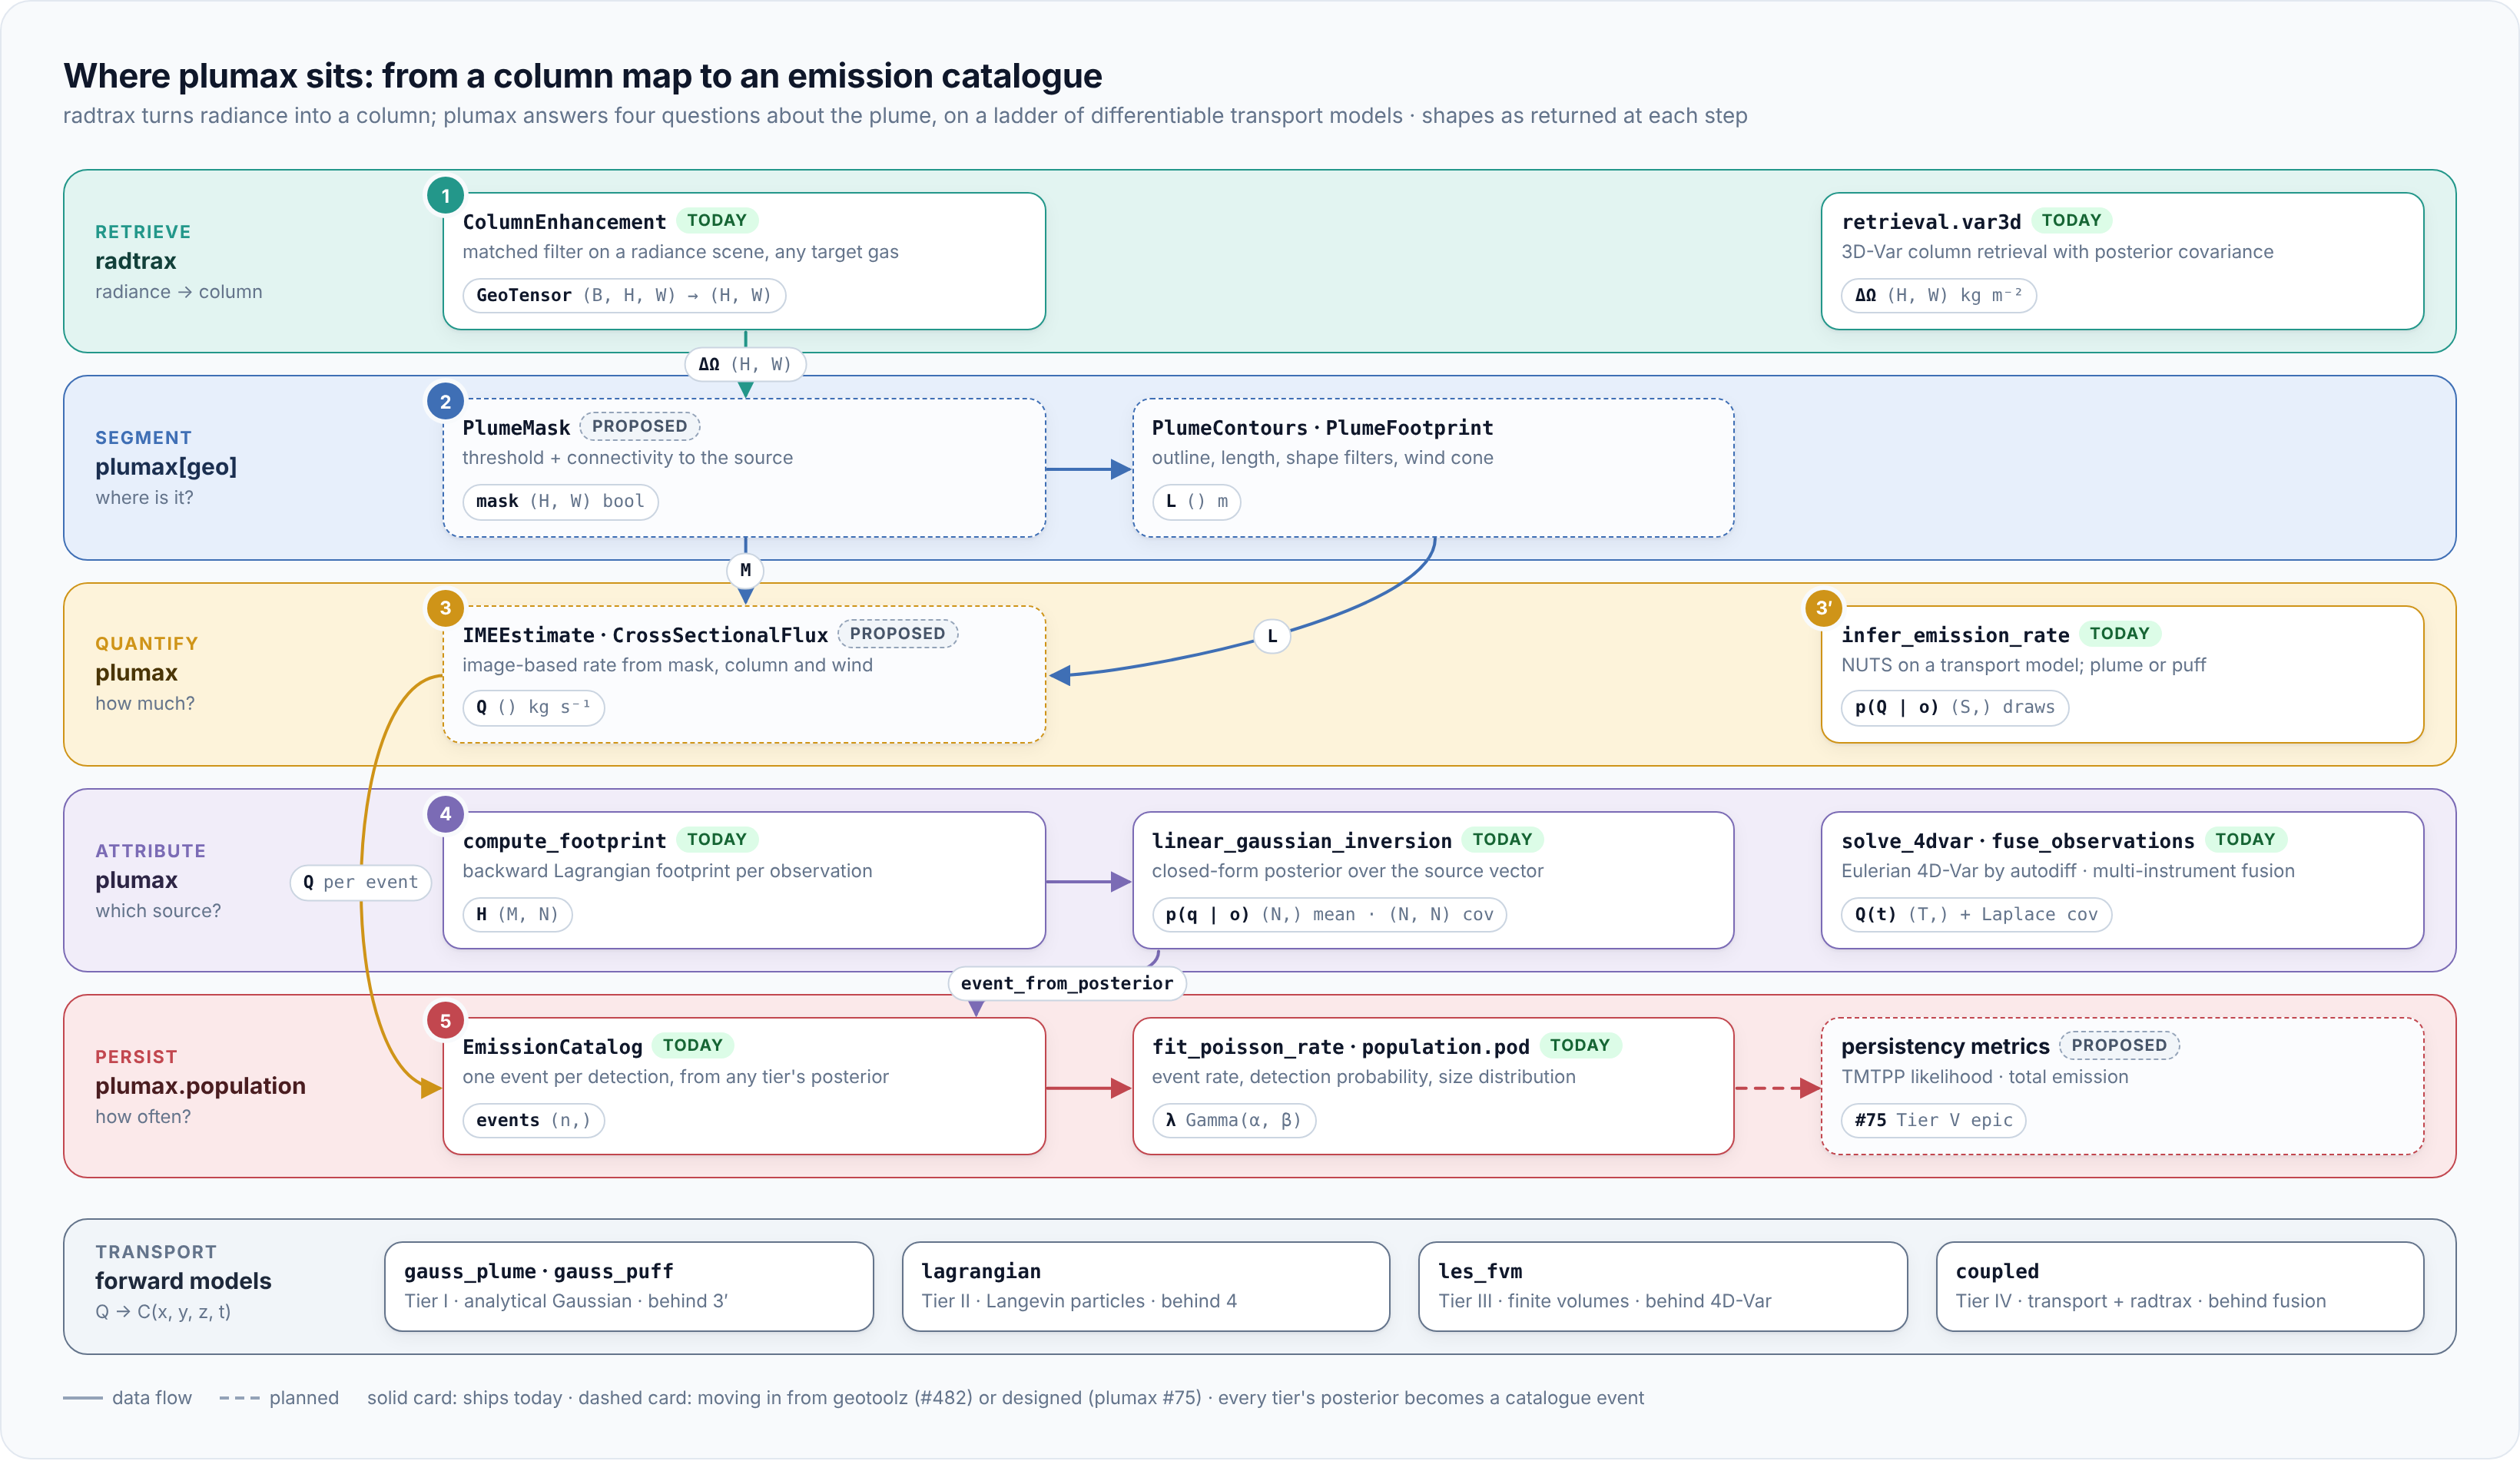
Figure 1:From a column map to an emission catalogue. Solid cards ship today; dashed cards are moving in from geotoolz or are designed but not built.
Four questions
| Question | Verb | Status |
|---|---|---|
| Where is the plume? | segment: mask, contours, footprint | 🚧 moving in from geotoolz |
| How much, in kg s⁻¹? | quantify: model inversion, IME, cross-sectional flux | ✅ inversion · 🚧 IME / flux |
| Which source? | attribute: footprints, 4D-Var, multi-instrument fusion | ✅ known source · 🚧 multi-source |
| How often, how long? | persist: event rates, detection probability, catalogues | ✅ rates · 🚧 persistency metrics |
✅ ships today · 🚧 designed, not shipped. The roadmap has the status of every tier.
Where plumax sits
Turning radiance into a column of gas is radiative transfer, and that lives
in radtrax. plumax takes the column,
or any concentration field, and reasons about the plume: its shape, its
transport and its source. plumax imports radtrax (the coupled tier maps a
simulated plume to radiance through it); radtrax never imports plumax.
| You want to… | Use |
|---|---|
| model a spectrum, build cross-section tables, run a matched filter or a 3D-Var column retrieval | radtrax |
| simulate where a released tracer goes | plumax (gauss_plume, gauss_puff, lagrangian, les_fvm) |
| estimate an emission rate or its uncertainty | plumax |
| mask, contour and measure a plume in an image | plumax [geo], moving from geotoolz |
| count events, model detection probability, extrapolate to a population | plumax (population) |
What it stands on
plumax sits in GeoStack’s GeoModels layer beside radtrax. It reaches down to
finitevolX for the Eulerian grid, to gaussx for every posterior covariance,
and to pipekit for the Operator interface. Inference sits to one side:
every tier exposes the same forward(params, met) → observations, so the
samplers and assimilation schemes are written once against it. NumPyro does
that for sampling; vardax (variational, the assim extra) runs the Tier II
optimal interpolation and the Tier III 3D-Var; filterax (ensemble Kalman) is
planned.
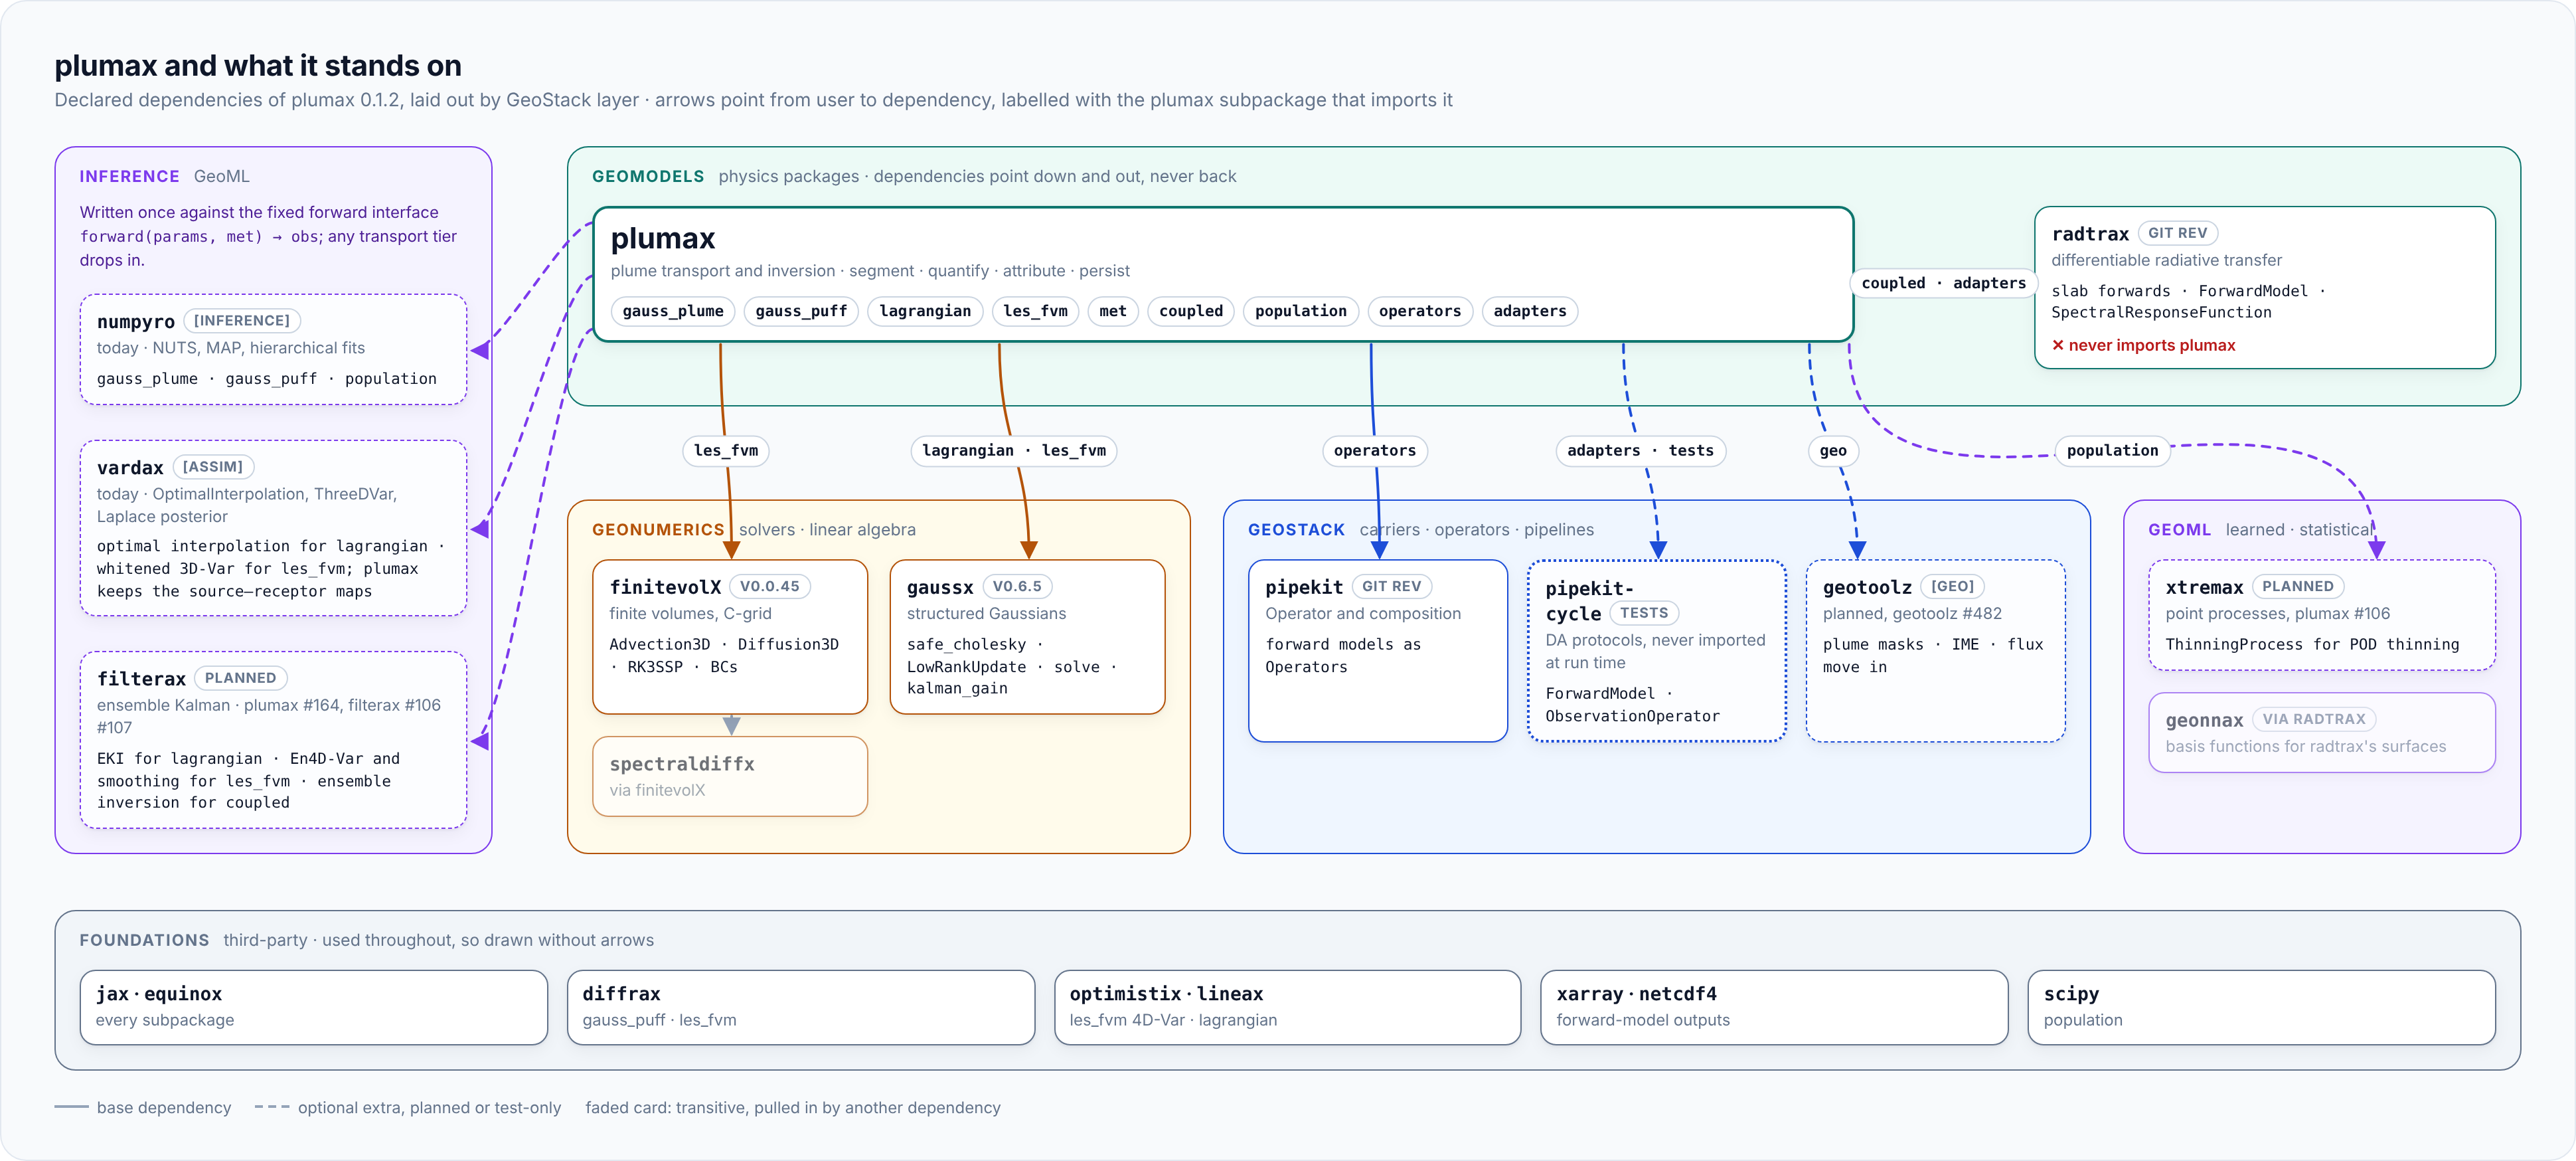
Figure 2:plumax’s declared dependencies by GeoStack layer. Each arrow is labelled with the plumax subpackage that imports the dependency.
The modeling cycle
plumax is organised around a five-tier data-driven modeling cycle. Each tier shares a fixed forward interface, so emulation and amortized inference are substitutions rather than rewrites:
Simple model: a generative story you can simulate from.
Model-based inference: slow but exact ground truth.
Model emulator: a fast surrogate (skip it if the model is cheap).
Emulator-based inference: step 2 in seconds.
Amortized inference: a predictor that learns the posterior map.
Improve: upgrade any component; the previous step is its ground truth.
The Roadmap & Architecture page has the tier breakdown (Gaussian → Lagrangian → Eulerian → Coupled → Population).
Installation
uv add plumaxgaussx, pipekit and radtrax are not yet on PyPI; from a checkout they
resolve from git via [tool.uv.sources]. NumPyro (Bayesian inference),
vardax (the Tier II and Tier III source inversions) and the notebook
dependencies are optional extras:
uv add "plumax[inference,assim]"Quickstart: simulate a plume, then recover its emission rate
A single stack 20 m tall releases a passive tracer at kg s⁻¹ into a 4 m s⁻¹ westerly, under Pasquill stability class C. The steady Gaussian plume gives the concentration [kg m⁻³] at a point , with downwind, crosswind, up, source height , wind speed , and the Briggs widths , of the stability class; the second exponential reflects the plume off the ground:
sensors at 5 m record , with a background and noise . NUTS samples the posterior over ; is the number of draws.
import jax
import jax.numpy as jnp
from plumax.gauss_plume import infer_emission_rate, simulate_plume

# Shapes: X = 100, Y = 80, Z = 13 grid points; K = 200 sensors; S = 500 draws

# today (plumax)
# C(x, y, z) on the grid, Q = 0.5 kg/s
truth = simulate_plume(                                  # → Dataset (X, Y, Z)
    emission_rate=0.5,
    source_location=(0.0, 0.0, 20.0),
    wind_speed=4.0,
    wind_direction=270.0,
    stability_class="C",
    domain_x=(0.0, 1000.0, 100),
    domain_y=(-200.0, 200.0, 80),
    domain_z=(0.0, 60.0, 13),
)

# every 40th grid column at z = 5 m
sensors = truth.concentration.isel(z=1).stack(k=("x", "y"))[::40]  # → (K,)

# oₖ = C(xₖ, yₖ, zₖ) + εₖ,  εₖ ~ 𝒩(0, s²)
noise = 2e-7 * jax.random.normal(jax.random.key(0), sensors.shape)  # (K,)
observed = jnp.asarray(sensors.values) + noise           # (K,) → (K,)
sensor_xyz = (
    jnp.asarray(sensors.x.values),
    jnp.asarray(sensors.y.values),
    jnp.full(sensors.shape, 5.0),
)

# today (plumax)
# p(Q, b | o) ∝ 𝒩(o; C_Q + b, s²I) · p(Q) · p(b)
posterior = infer_emission_rate(                         # → {Q: (S,), b: (S,)}
    observed,
    sensor_xyz,
    source_location=(0.0, 0.0, 20.0),
    wind_speed=4.0,
    wind_direction=270.0,
    stability_class="C",
    prior_mean=0.3,
    prior_std=0.3,
    obs_noise_std=2e-7,
    num_warmup=300,
    num_samples=500,
)

# 𝔼[Q | o], √Var[Q | o]
q = posterior["emission_rate"]                           # (S,)
print(f"Q = {q.mean():.4f} ± {q.std():.4f} kg/s")      # → Q = 0.5000 ± 0.0004 kg/s
simulate_plume and
infer_emission_rate in
the API reference list every parameter.
Not just methane
The transport and the inference treat a passive tracer: an emission rate in
kg s⁻¹ goes in, a concentration in kg m⁻³ comes out. Three places still
assume methane: coupled.rtm converts column mass to ΔVMR with
CH4_MOLAR_MASS_KG_PER_MOL; les_fvm labels its outputs “methane”; and the
population intensity kernels are named for methane sectors, although their
maths is sector-agnostic.